Two ears and 32 microphones: how an armored vehicle learns to hear FPV
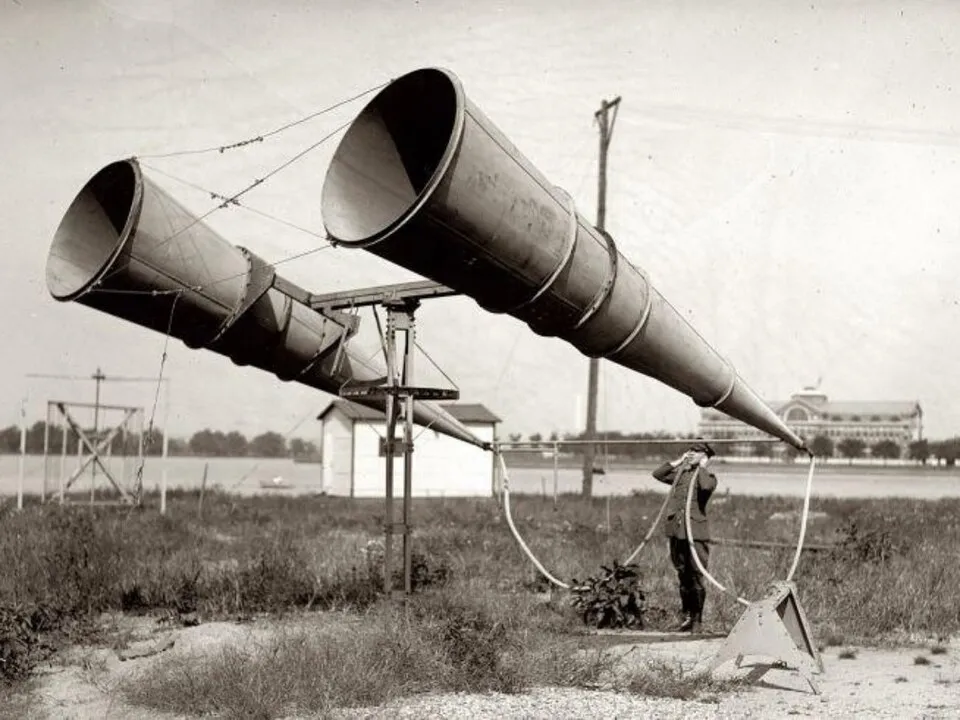
A WWI-era sonar operator would press two stethoscope tubes to his ears and rotate large horns. When the sound in the channels equalized, he would be directed toward the aircraft. A hundred years later, they're trying to entrust this same initial operation to a processor: only now there are no horns, dozens of microphones, and the device itself is driven by a machine that roars louder than the target.
The megaphone pointed where to look
The sonar device preserved at the Canadian War Museum operated next to 13-pounder anti-aircraft guns. Two horizontal horns were connected to stethoscope headphones. The operator compared the sound left and right and manually rotated the device. He obtained a bearing, but not a range, a precise trajectory, and certainly no automatic fire authorization.
The digital lattice has no direct lineage from this device. The similarity is limited to the task. The difference in sound arrival time came from artillery Sound metrics. Automatic event tagging and direction determination developed in gunshot detection systems. Spectral features and classification emerged in speech processing and machine learning.
For mobile vehicles, the experience of counter-sniper systems is especially important. Microflown manufacturer AVISA claims that ACLOGUS can localize shots while moving and distinguish external pulses from the carrier's noise. A propeller-driven UAV sounds different and takes much longer, so the algorithm can't simply be transferred. But the engineering conflict is already familiar: the sensor must detect an external source through the noise of its own vehicle.
The screw draws a comb, the engine erases it
A multicopter doesn't produce a single, pure note. The blades periodically pass through the airflow, the motor changes load, and the frame and arms vibrate. The spectrum displays the fundamental frequency of the blades and a chain of harmonics—the very comb by which a classifier tries to distinguish a UAV from a bird, a car, or a generator.
For a typical four-blade FPV at around 8–10 RPM, the fundamental blade frequency is in the 500–700 Hz range, with harmonics extending up to 2 kHz and higher. This is also where the main noise band of an armored vehicle's diesel engine falls: combustion noise, transmission tones, and track slams create a dense background noise in the 500–2000 Hz range. Simply cutting out the interfering band is doubly dangerous—the filter cuts off the carrier noise along with part of the target signal.
The picture changes as the aircraft climbs, maneuvers, shifts its load, and rotates. And on the roof of a military vehicle, the sounds of the engine, transmission, fans, and chassis are added. Oncoming airflow creates turbulence near the microphone, vibrations pass through the mount, and the turret and hull reflect sound. Therefore, the algorithm benefits from knowing the engine speed, load, gear, and carrier speed—without this context, filtering becomes a guessing game.
A single microphone can detect a familiar spectrum but is poor at determining direction. An array compares the delays of the same sound across different capsules and generates a bearing. The larger the aperture, the more reliably the system distinguishes close directions at low frequencies—and the more space it requires on the roof.
An acoustic vector sensor takes a different approach. It measures not only pressure but also the movement of air particles, allowing direction to be obtained with a more compact unit. This principle is used in the CASTLE SKYSENTRY system. Microflown's design calls for the sensor to provide azimuth and elevation data to deploy another sensor or countermeasure. This already reveals the limits of technology: acoustics tell you where to look, but not how far to shoot.
The signature is not a constant
The algorithm's dependence on a stable spectral comb works both ways. Impact platform developers read the same technical publications. Switching to a damped frame, changing the blade pitch, or reducing RPM on the final leg of the flight shifts or blurs the characteristic peaks. The Israeli Aerosol G2 reconnaissance drone produces approximately 14,9 dB at a range of one kilometer—below the level of a moderate wind in foliage. This isn't the limit of acoustic engineering; it's a reminder that signature is a controllable parameter, not a physical constant. The broader and more detailed the classifier's training database, the stronger the incentive to create a drone that doesn't exist.
For an open range with a single test multicopter, this threat is still abstract. For combat use, it has already been formulated in the enemy's design specifications.
An open range poses another problem that testing avoids. In an urban ravine, a forest belt, or among the armored hulls of adjacent vehicles, the sound wave doesn't reach the array via a single path: it reflects off walls, trees, and metal. The algorithm that calculates the bearing based on the difference in delays sees multiple versions of the same pulse with different arrival times. A simple correlator mistakes delayed reflections for separate sources or miscalculates their direction. Multipath suppression requires a separate processing layer and a priori data on the surrounding geometry—something a system on the move typically lacks.
Thirty-two ears are driving along a dirt road
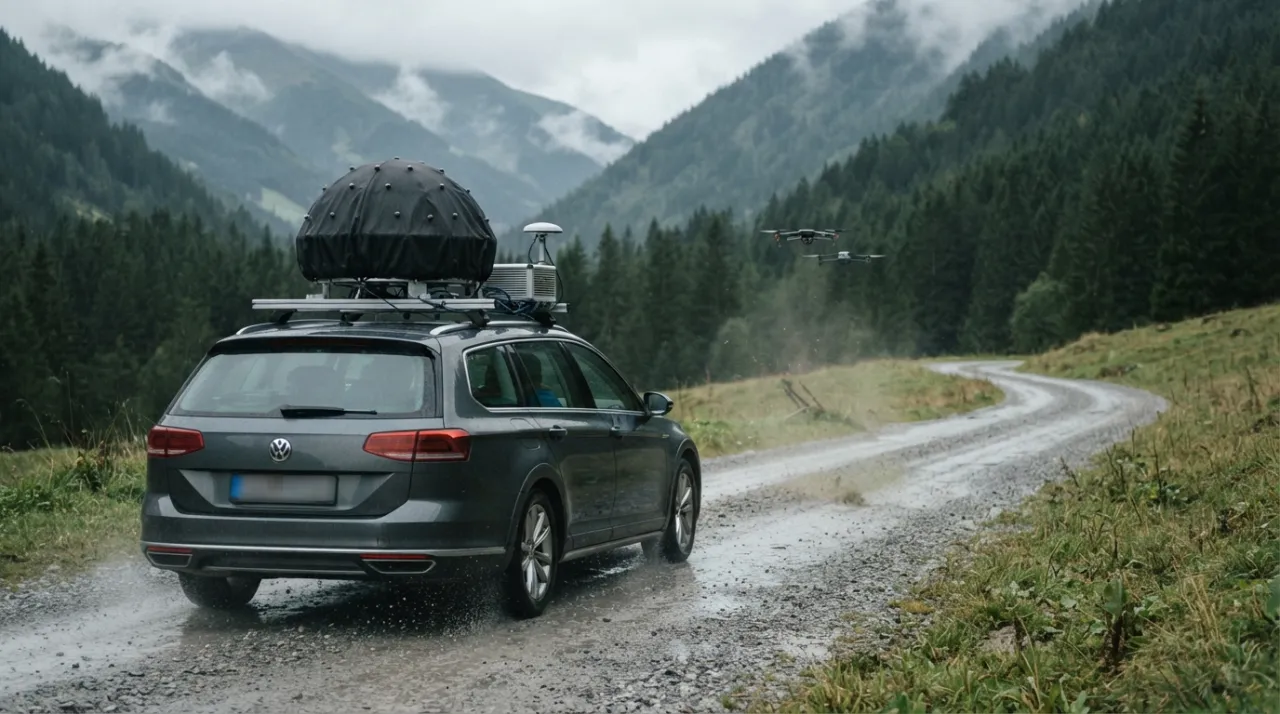
Martin Blass, Stefan Grebien and Franz Graf from JOANNEUM RESEARCH described the mobile complex in action Experimental Evaluation of Acoustic Drone Tracking using Mobile Microphone ArraysA hemispherical JR-IcoDome32 array, approximately one meter in diameter, was installed on the vehicle's roof. The system included 32 microphones, a windscreen, vibration isolation, a GNSS/IMU module, synchronized audio interfaces, and a dedicated computer. The experimental configuration consumed approximately 120 watts.
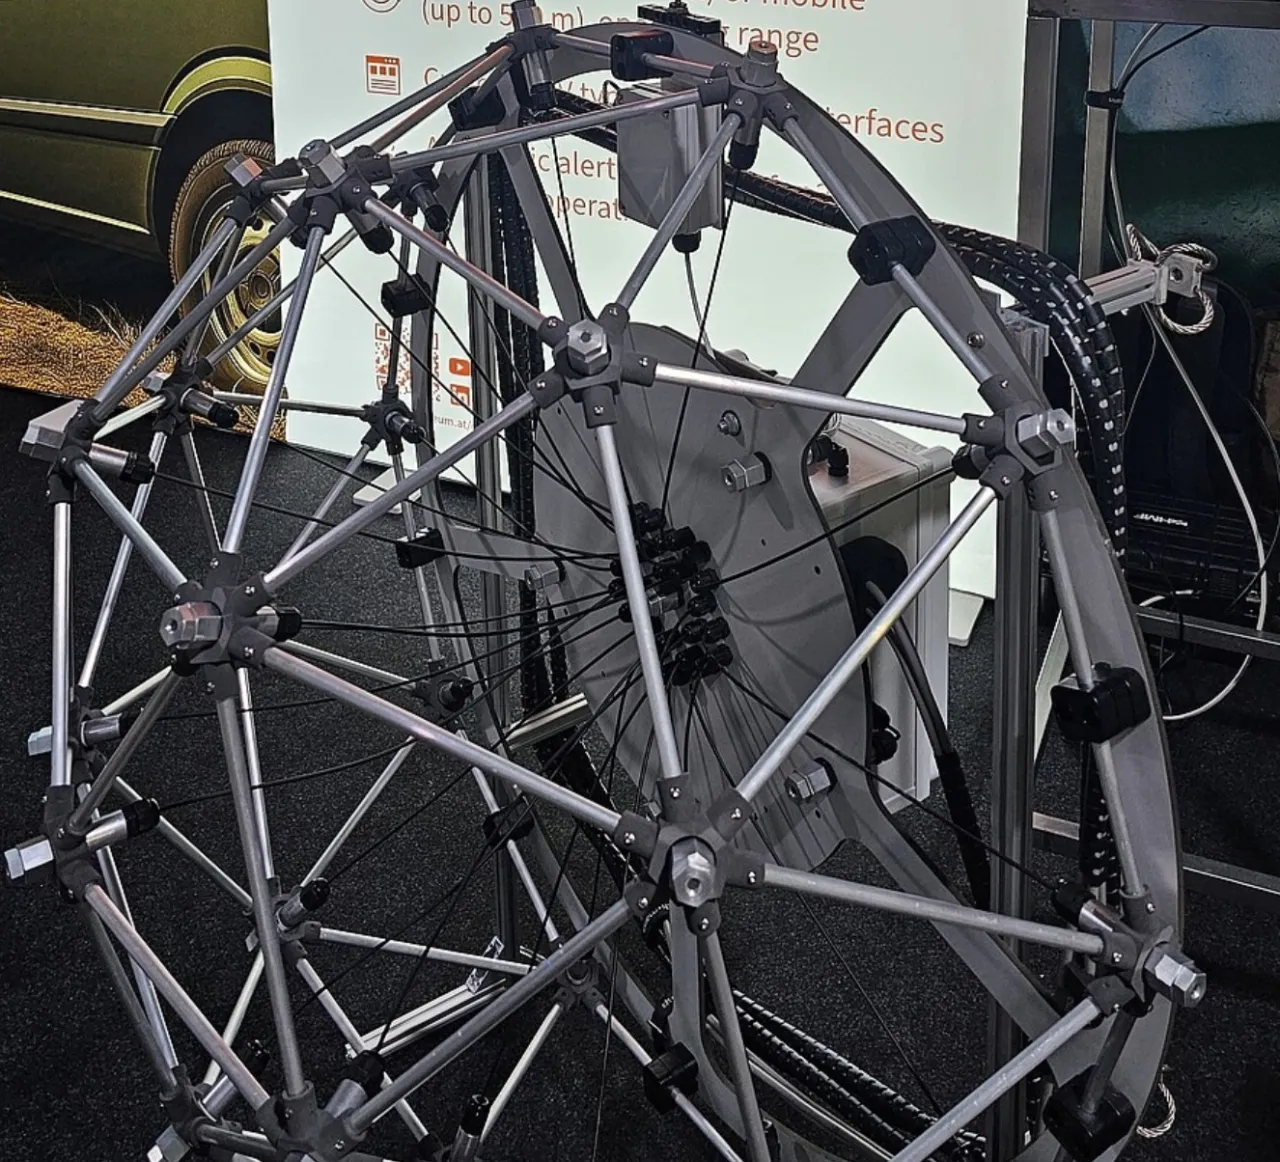
32 microphones on a meter-long sphere – JR-IcoDome32 from Joanneum Research in Graz
The vehicle traveled along a dirt road at speeds of 10, 20, and 30 km/h. Three types of multicopters were tested individually. For most configurations, the median heading error remained less than 10° when stationary and less than 30° when moving; the small six-microphone subarray performed worse. Conventional GNSS and IMUs without differential correction could introduce their own errors.
This experiment demonstrated not "long-range hearing," but something more modest and useful: the UAV's direction can be maintained even from a moving vehicle. The price of mobility became immediately apparent: accuracy deteriorated, the equipment took up significant space, and the vehicle required a separate measuring circuit.
All published experiments were conducted with a single device simultaneously. For swarm attacks—when multiple FPVs enter from different sectors during a single time period—no data on the direction finder's performance has been published in open sources. Some commercial platforms claim to track up to 16 targets simultaneously, but this figure reflects specially selected testing conditions, not a running diesel engine and potholes on a dirt road.
In June 2026, Militär Aktuell reported on tests at speeds of 40–50 km/h. According to the publication, the mobile range dropped to approximately a third of the stationary range. The current setup consumed approximately 100 watts, and the developers wanted to reduce the power consumption of the future configuration with MEMS microphones and an integrated computer to below 50 watts. These figures are consistent with academic experience: they refer to the next stage of the experimental platform.
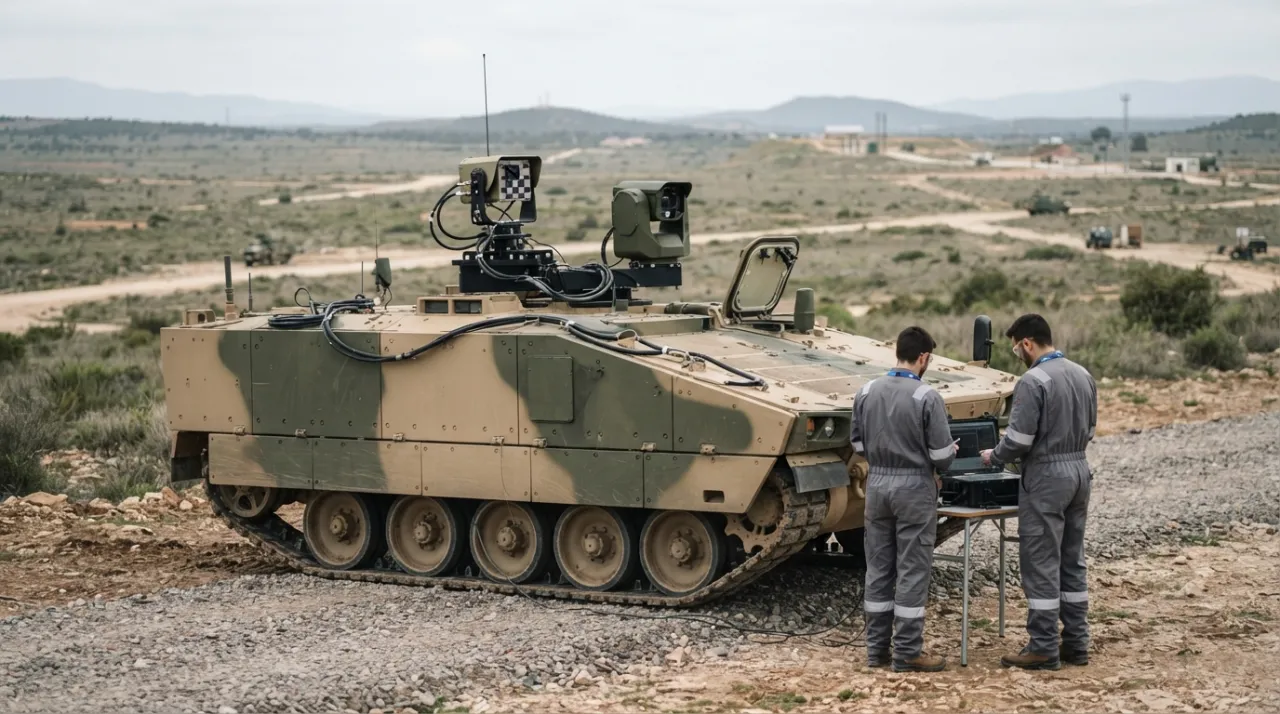
There was still one more step to go before the armored vehicle. In April 2026, General Dynamics European Land Systems, together with Microflown AVISA, demonstrated the CASTLE on a tracked ASCOD against non-commercial FPV-dronesThe event status is proof of concept. The public release does not include the carrier's speed, engine mode, detection probability, false alarm rate, or the number of simultaneously processed targets. The sensor has reached the tracked platform; this does not mean it will become a standard production system.
A record distance always requires a passport.
For the CASTLE, the manufacturer cites a range of up to 250 m for a 2 kg quadcopter and up to 1 km for a fixed-wing UAV of the same weight. These aren't two versions of the same specification. The devices differ in their propellers, motors, flight mode, and noise direction. Microflown itself specifies the impact of wind speed and direction.
Brendan Harvey and Sue O'Young at work Acoustic Detection of a Fixed-Wing UAV In 2018, we achieved a maximum range of 678 m. However, the microphones were on a flying electric aircraft, and the target was a loud, gasoline-powered Giant Big Stik weighing 6,5 kg. The average range was 302 m. The longest-range processing option yielded an impractical false alarm rate; a more robust design reduced these false alarms at the cost of a moderate reduction in range. For small FPV applications near a running diesel engine, the record promises nothing.
There's another trap. Gabriel Jekateryńczuk and Zbigniew Piotrowski are working on it. Outdoor Microphone Range Tests and Spectral Analysis of UAV Acoustic Signatures for Array Development Microphones were compared outdoors. Some ranges were determined using a calibrated 1 kHz tone at a given signal-to-noise ratio. This test effectively demonstrates the hardware, wind protection, and capsules, but does not equate to the range of reliable detection of an attacking drone. The authors identified wind as the dominant limiter: even moderate gusts increased background noise and reduced the range.
A neural network doesn't eliminate this physics. A new propeller, payload, wet snow, an unfamiliar engine, or a tracked chassis all change the input data. If the training set is collected on a quiet test site, high classification accuracy may be lost with the first operational vehicle. Therefore, it's useful for the algorithm to know the engine speed, load, gear, and vehicle speed, and some interference must be mechanically suppressed—by enclosure, decoupling, and installation location.
The microphone should rotate the camera, not the trigger.
Sound travels at approximately 343 m/s. With a detection range of 150 m, the wavefront reaches the sensor in approximately 437 ms—before processing even begins. Taking into account data accumulation, spectral analysis, and classification, the total delay before sector output easily exceeds half a second. FPV, traveling at 20 m/s, shifts more than 10 m during this time. For targeting weapons — is already irreparable; for rotating the optical axis with a sufficiently wide field of view, it's perfectly acceptable. Acoustic bearings cannot be converted into a ready-made track: they lack reliable range and are already somewhat outdated.
A practical architecture divides responsibilities. Acoustics passively detects a characteristic source and generates a sector. An electro-optical/infrared (EO/IR) camera steers toward it and confirms the object. A small radar measures range and speed. A radio frequency channel searches for control, telemetry, or video transmission. Several vehicles or dispersed outposts can intersect the bearings and refine the coordinates.
Here, the acoustics have a property that's usually not mentioned first in technical reviews. The sensor emits nothing. A vehicle with a working radar or active RF detector announces its presence to any passive interceptor within a radius of several kilometers. The microphone array is electromagnetically silent: its presence cannot be detected by either an electronic reconnaissance station or a passive receiver onboard a UAV. For vehicles that are not allowed to "show" themselves, this is a significant detail.
RF analysis is the prime candidate for a passive warning channel: it's faster, has a longer range, and typically pinpoints the source to its coordinates. However, it has a blind spot that acoustics fill. A fiber-optic-guided drone doesn't reveal itself in the radio spectrum at all; autonomous route flight without an active telemetry channel makes it invisible to protocol detectors. It's precisely these applications—a quiet, radio-silent UAV on the final leg of its flight—that create a practical niche for acoustics that RF doesn't fill.
SKYSENTRY is explicitly designed for this role, and the Discovair G2+'s optical camera is already integrated with a 128-microphone array. However, the readiness of individual components does not equate to the readiness of the armored vehicle's protection. This requires a comprehensive test: the engine is running, the platform is moving over rough terrain, the vehicle's own weapon is generating pulse interference, and multiple targets are appearing from different directions. The result should include the probability of detection, false alarm rate, angular error, and sector acquisition time.
The publicly available materials collected do not confirm a mass-produced Russian onboard system of this class. This does not prove its absence, but it prohibits the use of a convenient title in the article. For domestic technology, the conclusion is currently formulated as a technical specification: the passive sensor must recognize FPV through a specific engine and chassis, survive a shot from its own vehicle, resist a swarm, and transmit a sector to existing optics or radar.
A hundred years ago, the operator would rotate the horns until the sound in the two headphones was equal. A modern array must perform the same initial step more quickly—and rotate the camera, not the weapon. The acoustics will earn a place on the armor when they maintain this field of view while moving, in urban reflections, and with simultaneous targets, demonstrating a measurable false alarm rate; until such a test, they remain a useful warning channel, not a ready-made targeting device.
Information